AI is like a car. RIG is the 1000x car.
How AI actually works
AI isn't one engine. It's a network of governed subsystems, like a Formula 1 car.
AI is like a car. RIG is the 1000x car. How AI actually works AI isn't one engine. It's a network of governed subsystems, like a Formula 1 car.The 1000x leap isn't a bigger engine. It's the architecture.
Start with a free 30-minute initial assessment → ↺ Replay the teardownDecoupled subsystems, a standardized plug-in bus, a model swarm, and brakes between the engine and the road. That's what turns a car into a 1000x car, and what RIG ships.
The 1000x leap isn't a bigger engine. It's the architecture. Decoupled subsystems, a standardized plug-in bus, a model swarm, and brakes between the engine and the road. That's what turns a car into a 1000x car, and what RIG ships. Start with a free 30-minute initial assessment → ↺ Replay the teardownThe written teardown, in 3D
Pop the hood. Eight subsystems, one machine.
The same map the article uses, drawn in geometry. A modern AI system maps onto the subsystems of a race car, and the mapping is load-bearing: it tells you where to look when the thing underperforms.
topbar
topbar RIG · Rodgers Intelligence Group Start with a free 30-minute initial assessment →Engine & Drivetrain → Foundation Models
ECU & Wiring Harness → Orchestration + MCP
Sensors & Cameras → Context and GraphRAG
ADAS → Guardrails & Eval Gates
Dashboard & Pedals → Human-in-the-Loop
Navigation → Observability, the hub
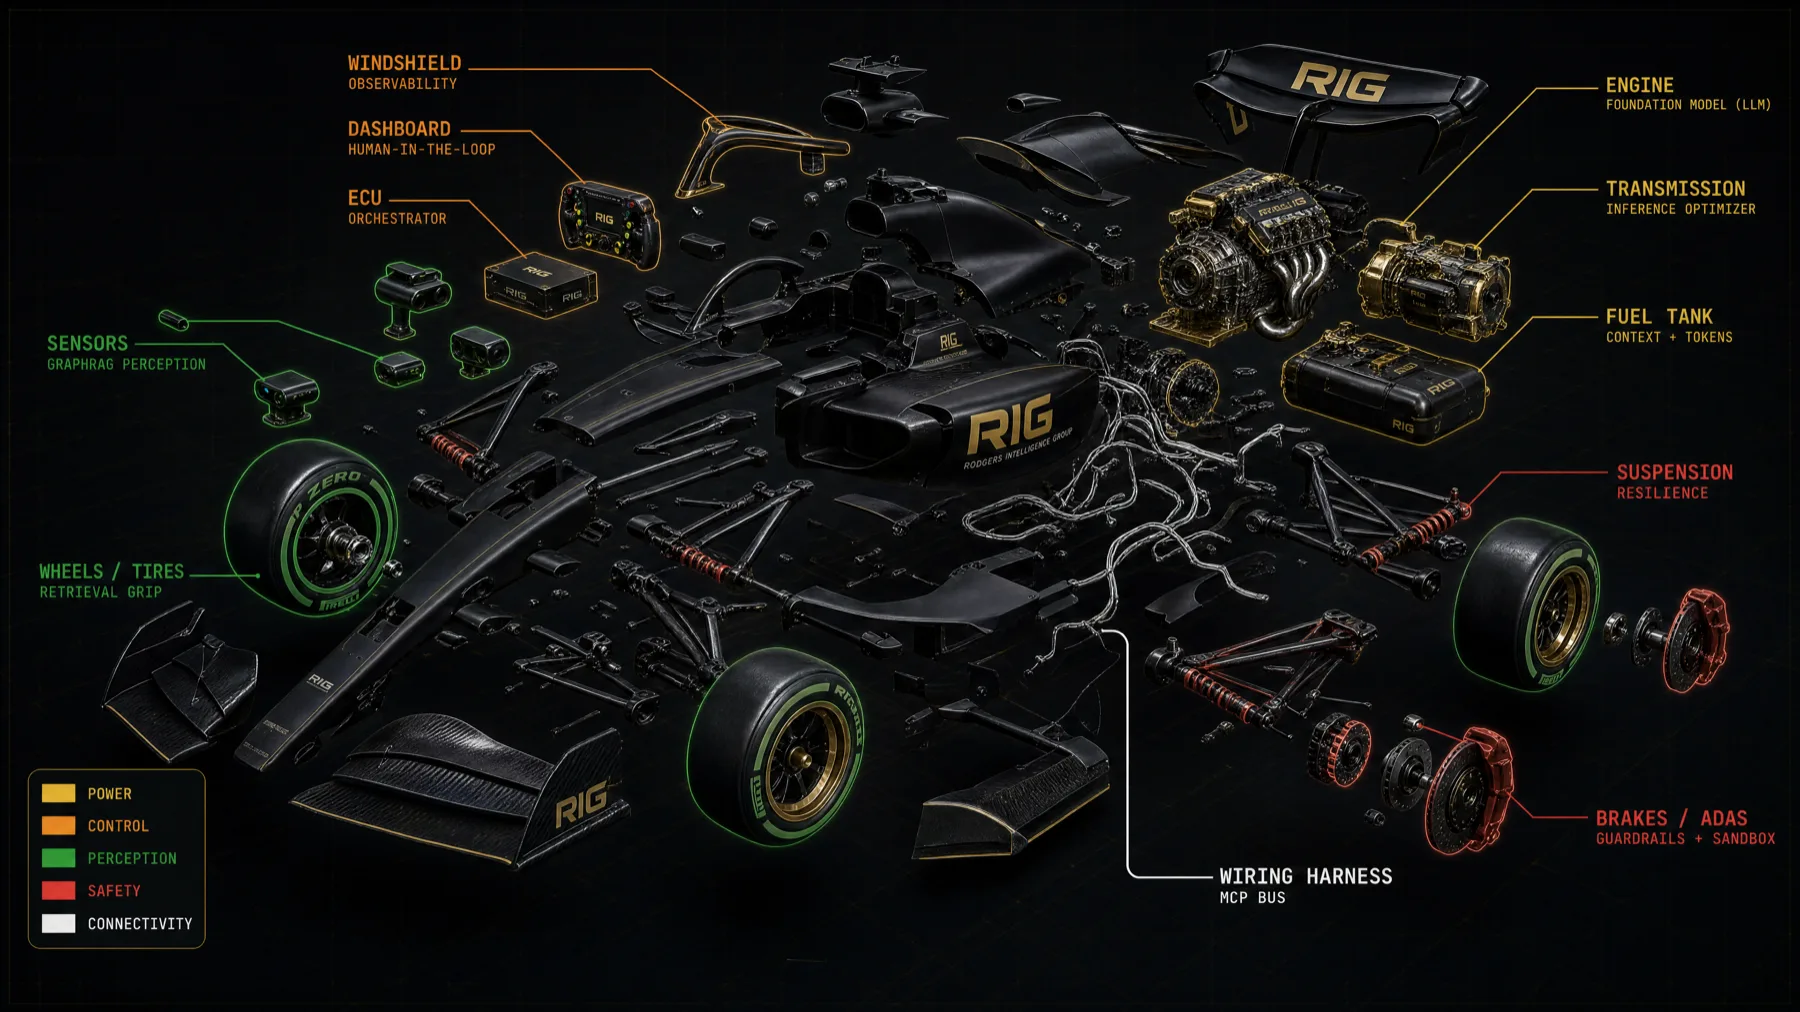
Start with a free 30-minute initial assessment → Exploded technical diagram of a matte-black RIG Formula 1 car, every component floating apart and color-coded to an AI subsystem: gold power (engine/transmission/fuel), green perception (sensors/wheels), red safety (brakes/suspension), white connectivity (wiring harness), amber control (ECU/dashboard). AI is like a car. RIG is the 1000x car. A car is not a single engine. It's a network of isolated, specialized systems working together under a unified control loop. A modern AI system maps directly onto the subsystems of an automobile. The deeper principle is slice engineering: you build functional, testable subsystems (the braking assembly, the fuel delivery system) not all 40,000 bolts at once. Keep the engine (back end) isolated from the dashboard (front end), connected by a wiring harness (APIs and protocols). Engine & Drivetrain → Foundation Models ENGINE = the LLM · TRANSMISSION = inference tuners The engine makes raw horsepower but can't steer, brake, or read road signs on its own. The LLM is core reasoning torque; the transmission (vLLM, TensorRT) translates that raw power into usable speed so the agent runs efficiently without stalling. ECU & Wiring Harness → Orchestration + MCP WIRING HARNESS = APIs & the Model Context Protocol The ECU (orchestrator) runs the reason-act loop and decides when to shift from thinking to doing. The wiring harness routes signals between front end, back end, and external tools, without exposing raw credentials to the passenger cabin. New capability becomes a snap-in MCP module, not a rewrite. Sensors & Cameras → Context and GraphRAG SENSORS = retrieval · FUEL TANK = the context window Cameras and radar (retrieval) scan the environment (internal docs, the web, databases) feeding real-time road data to the engine so it doesn't crash into hallucinations. The 1000x move replaces basic vector search with GraphRAG and agentic memory: the fuel tank becomes a reactor. ADAS → Guardrails & Eval Gates BRAKES = guardrails + deterministic fallbacks + sandbox Lane-keep assist (I/O guardrails) keeps the agent from veering into toxic or hallucinated territory. ABS braking (deterministic fallbacks) catches malformed output and forces a safe retry. The digital twin (a sandboxed simulation) runs linters, scanners, and tests before anything reaches production. Dashboard & Pedals → Human-in-the-Loop DASHBOARD = the front end + observability The steering wheel and pedals are where a human issues intent or intervenes. The instrument cluster (streaming thoughts, execution logs, token-usage meters) is transparency into what the agent is thinking. Navigation → Observability, the hub NAVIGATION = the master feedback loop Navigation is the hub: every slice emits a signal (grip, satisfaction, crashes, cost, misfires) that converges here, becomes an eval case, and routes back to its owning subsystem. That cybernetic loop is what makes the chassis learn the road rather than just drive it. The takeaway: the 1000x leap isn't a bigger engine. It's architecture. Start with a free 30-minute initial assessment →Exploded technical diagram of a matte-black RIG Formula 1 car, every component floating apart and color-coded to an AI subsystem: gold power (engine/transmission/fuel), green perception (sensors/wheels), red safety (brakes/suspension), white connectivity (wiring harness), amber control (ECU/dashboard).
Engine & Drivetrain → Foundation Models
ECU & Wiring Harness → Orchestration + MCP
Sensors & Cameras → Context and GraphRAG
ADAS → Guardrails & Eval Gates
Dashboard & Pedals → Human-in-the-Loop
Navigation → Observability, the hub
A car is not a single engine. It's a network of isolated, specialized systems working together under a unified control loop. A modern AI system maps directly onto the subsystems of an automobile. The deeper principle is slice engineering: you build functional, testable subsystems (the braking assembly, the fuel delivery system) not all 40,000 bolts at once. Keep the engine (back end) isolated from the dashboard (front end), connected by a wiring harness (APIs and protocols).
The engine makes raw horsepower but can't steer, brake, or read road signs on its own. The LLM is core reasoning torque; the transmission (vLLM, TensorRT) translates that raw power into usable speed so the agent runs efficiently without stalling.
The ECU (orchestrator) runs the reason-act loop and decides when to shift from thinking to doing. The wiring harness routes signals between front end, back end, and external tools, without exposing raw credentials to the passenger cabin. New capability becomes a snap-in MCP module, not a rewrite.
Cameras and radar (retrieval) scan the environment (internal docs, the web, databases) feeding real-time road data to the engine so it doesn't crash into hallucinations. The 1000x move replaces basic vector search with GraphRAG and agentic memory: the fuel tank becomes a reactor.
Lane-keep assist (I/O guardrails) keeps the agent from veering into toxic or hallucinated territory. ABS braking (deterministic fallbacks) catches malformed output and forces a safe retry. The digital twin (a sandboxed simulation) runs linters, scanners, and tests before anything reaches production.
The steering wheel and pedals are where a human issues intent or intervenes. The instrument cluster (streaming thoughts, execution logs, token-usage meters) is transparency into what the agent is thinking.
Navigation is the hub: every slice emits a signal (grip, satisfaction, crashes, cost, misfires) that converges here, becomes an eval case, and routes back to its owning subsystem. That cybernetic loop is what makes the chassis learn the road rather than just drive it.
The takeaway: the 1000x leap isn't a bigger engine. It's architecture. Start with a free 30-minute initial assessment →
Engine & Drivetrain → Foundation Models ECU & Wiring Harness → Orchestration + MCP Sensors & Cameras → Context and GraphRAG ADAS → Guardrails & Eval Gates Dashboard & Pedals → Human-in-the-Loop Navigation → Observability, the hub A car is not a single engine. It's a network of isolated, specialized systems working together under a unified control loop. A modern AI system maps directly onto the subsystems of an automobile. The deeper principle is slice engineering: you build functional, testable subsystems (the braking assembly, the fuel delivery system) not all 40,000 bolts at once. Keep the engine (back end) isolated from the dashboard (front end), connected by a wiring harness (APIs and protocols). The engine makes raw horsepower but can't steer, brake, or read road signs on its own. The LLM is core reasoning torque; the transmission (vLLM, TensorRT) translates that raw power into usable speed so the agent runs efficiently without stalling. The ECU (orchestrator) runs the reason-act loop and decides when to shift from thinking to doing. The wiring harness routes signals between front end, back end, and external tools, without exposing raw credentials to the passenger cabin. New capability becomes a snap-in MCP module, not a rewrite. Cameras and radar (retrieval) scan the environment (internal docs, the web, databases) feeding real-time road data to the engine so it doesn't crash into hallucinations. The 1000x move replaces basic vector search with GraphRAG and agentic memory: the fuel tank becomes a reactor. Lane-keep assist (I/O guardrails) keeps the agent from veering into toxic or hallucinated territory. ABS braking (deterministic fallbacks) catches malformed output and forces a safe retry. The digital twin (a sandboxed simulation) runs linters, scanners, and tests before anything reaches production. The steering wheel and pedals are where a human issues intent or intervenes. The instrument cluster (streaming thoughts, execution logs, token-usage meters) is transparency into what the agent is thinking. Navigation is the hub: every slice emits a signal (grip, satisfaction, crashes, cost, misfires) that converges here, becomes an eval case, and routes back to its owning subsystem. That cybernetic loop is what makes the chassis learn the road rather than just drive it. The takeaway: the 1000x leap isn't a bigger engine. It's architecture. Start with a free 30-minute initial assessment →